
Closed-Loop Robotic Control
FAIR 1 Archive Notice
This page describes research activities and results from the FAIR 2019-2023 program period.
The content is retained for reference purposes and is no longer actively maintained. Information on this page, including research outputs, team members, contact details, collaborations and links, may be incomplete or outdated.
No direct successor use case has been defined within the FAIR 2024-2028 program. Please consult the current FAIR use cases for related research activities.
Use Case Description
In this use case, we focus on equipping a cobot with AI-technology to learn grasping objects. Robots optimized for high throughput production are engineered for one specific task and it is therefor difficult and costly to adapt these to new tasks or environments. Contrary to this, we envisage a flexible set-up, where the AI-subsystem learns to cope with varying circumstances and task variations.
In this respect, it is crucial that the AI can control the cobot with low latency, i.e. the time to take a decision on an action should be small. We designed the full perception-decision-action pipeline and performed a wide architecture search to achieve real-time robotic control.
Results-Artefacts
Demonstrator
Real-time control for Push-Grasp task
Tangible Result
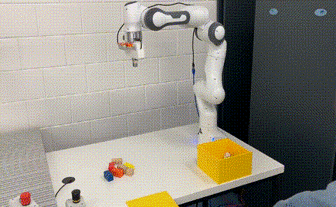
The task for the cobot consists of pushing and grasping random objects on the workspace, and collecting this in a container. The resulting deep network is a combination of a careful accuracy-complexity trade-off, and is based on pruning the original network as well as on weight quantization. This resulted in a 300x speed up with respect to the baseline architecture, allowing to control the system at a 60 Hz pace.
Journal/Conference Publications
Ferraro, Stefano, Toon Van de Maele, Pietro Mazzaglia, Tim Verbelen, and Bart Dhoedt. 2022. “Computational Optimization of Image-Based Reinforcement Learning for Robotics.” Edited by Anastasios Doulamis. SENSORS 22 (19). https://doi.org/10.3390/s22197382.
PhDs
Stefano Ferraro
Toon Van de Maele
Outreach
External events/workshops
Presentation/DEMO at "Festival van de Toekomst" (Nov 2, 2023, Aalst)
https://festivalvandetoekomst.be
Basic Use Case Info
Period
2019-2023
Contact
Bart Dhoedt, Ghent University, IDlabBart Dhoedt, Ghent University, IDlab
Research Groups
IDlab, https://idlab.technology
What's next?
Autonomous Systems